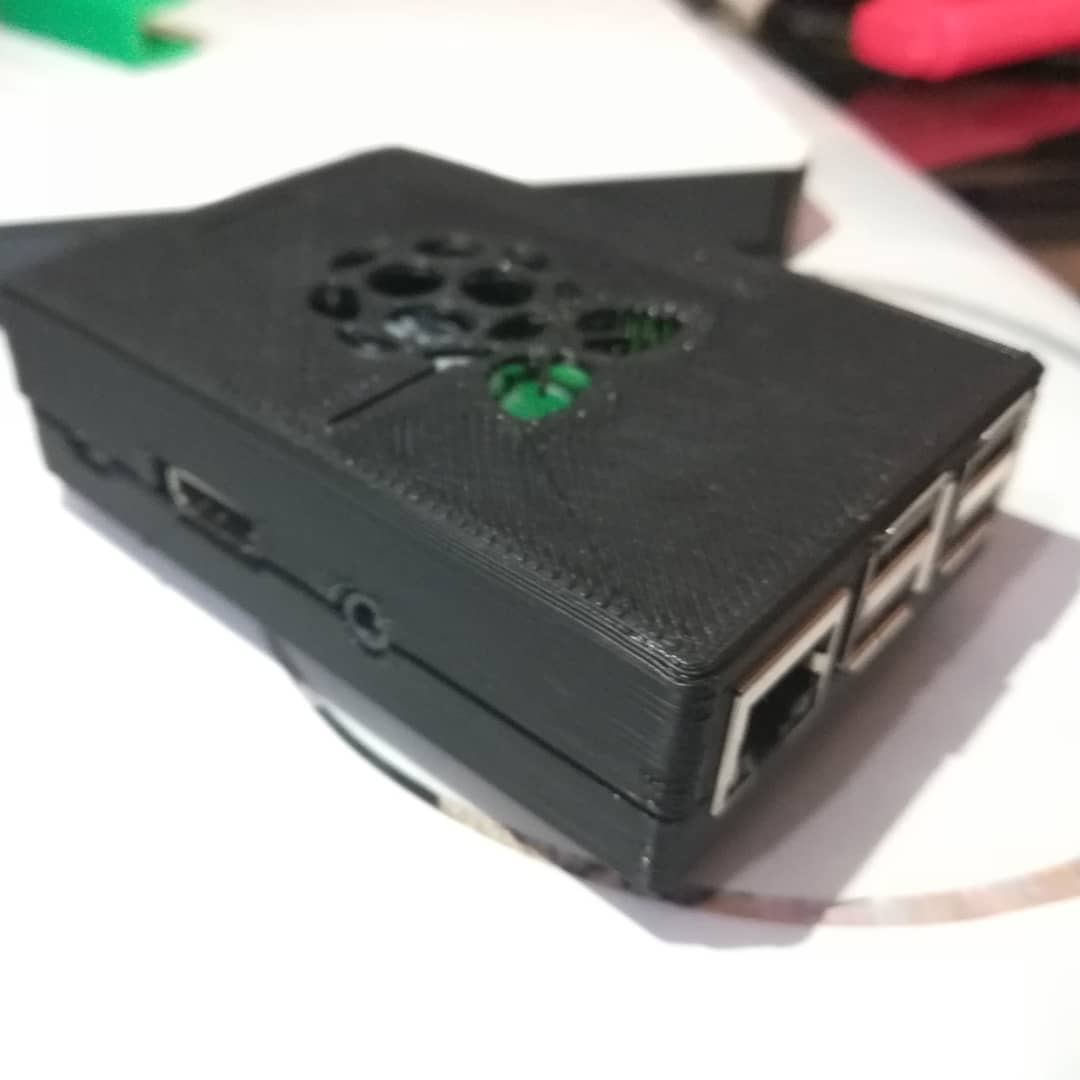
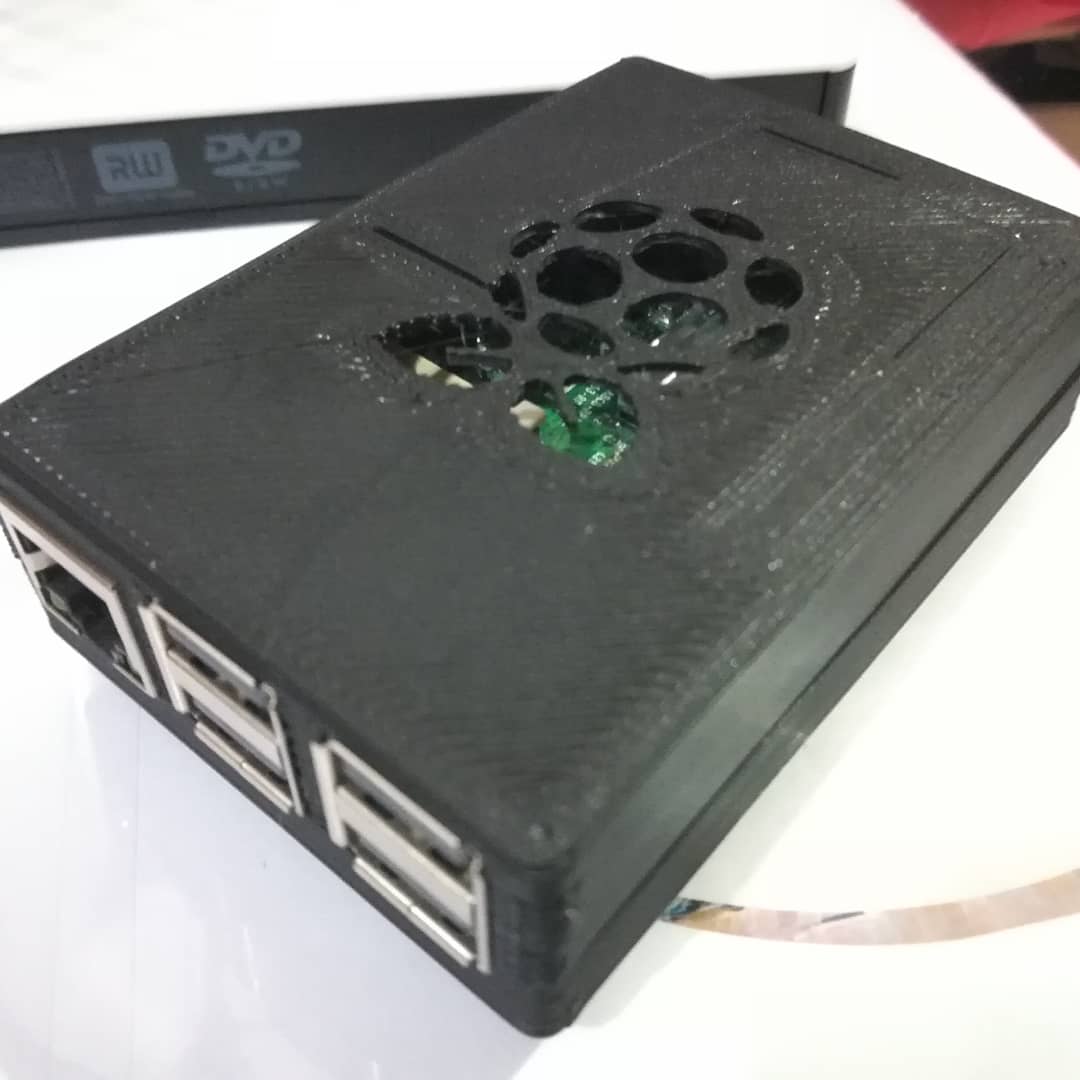
Oggi (14.10.2020) ho modificato il file fan_controller.py per impostare la FanHat Melopero del Raspberrypi4 con Kodi in modo che non partisse in automatico all’avvio, e si attivasse solo superata una certa temperatura.
Dato che ho intensione di tenere il Rpi sempre acceso non aveva senso che continuasse a girare anche quando non lo stavo usando.
File originale
!/usr/bin/env python3
import sys
sys.path.append(‘/storage/.kodi/addons/virtual.rpi-tools/lib’)
import os
import time
import RPi.GPIO as GPIO
import glob
minimum_always_ON=True
minimum_speed=30
target_temp=52
current_speed=0
thermal_zones_temp_dirs=glob.glob(“/sys/class/thermal/thermal_zone*/temp”)
def getCPUtemperature():
res = os.popen(‘vcgencmd measure_temp’).readline()
#vcgencmd measure_temp -> res=”temp=NN.N’C\n”
#temp =(res.replace(“temp=”,””).replace(“‘C\n”,””))
temp=res[5:9]
try :
temp= float(temp)
except :
print(“vcgencmd measure_temp failed”)
temp=getCPUTemperature2()
return tempdef getCPUTemperature2():
temps=[]
for file_dir in thermal_zones_temp_dirs:
with open(file_dir, “r”) as file:
try :
temps.append(float(file.read()))
except :
print(“Error reading from file {}”.format(file_dir))
continue
if len(temps) == 0:
    print("reading from sys files failed, no CPU temp detected using target_temp")
    temps.append(target_temp * 1000)

return max(temps) / 1000
try:
GPIO.setmode(GPIO.BCM)
GPIO.setup(18, GPIO.OUT)
myPWM=GPIO.PWM(18,50)
myPWM.start(minimum_speed)

current_speed=minimum_speed

while True:
    temp = getCPUtemperature()

    if(temp<target_temp and not minimum_always_ON):
        myPWM.ChangeDutyCycle(0)
        current_speed=0
        time.sleep(1)
        continue
    if(temp<target_temp and minimum_always_ON):
        myPWM.ChangeDutyCycle(minimum_speed)
        current_speed=minimum_speed
        time.sleep(1)
        continue

    if(temp>target_temp and temp<56):
        myPWM.ChangeDutyCycle(40)
        current_speed=40
        time.sleep(1)
        continue
    if(temp>56 and temp<60):
        myPWM.ChangeDutyCycle(50)
        time.sleep(1)
        continue
    if(temp>60 and temp<65):
        myPWM.ChangeDutyCycle(60)
        current_speed=60
        time.sleep(1)
        continue
    if(temp>65 and temp<70):
        myPWM.ChangeDutyCycle(70)
        current_speed=70
        time.sleep(1)
        continue
    if(temp>70 and temp<74):
        myPWM.ChangeDutyCycle(80)
        current_speed=80
        time.sleep(1)
        continue
    if(temp>74 and temp<76):
        myPWM.ChangeDutyCycle(90)
        current_speed=90
        time.sleep(1)
        continue
    if(temp>76):
       #handleFan(100)
        myPWM.ChangeDutyCycle(100)
        current_speed=100
        time.sleep(1)
        continue
except KeyboardInterrupt: # trap a CTRL+C keyboard interrupt
GPIO.cleanup() # resets all GPIO ports used by this program
File modificato
!/usr/bin/env python3
import sys
sys.path.append(‘/storage/.kodi/addons/virtual.rpi-tools/lib’)
import os
import time
import RPi.GPIO as GPIO
import glob
minimum_always_ON=True
minimum_speed=30
target_temp=50
current_speed=0
thermal_zones_temp_dirs=glob.glob(“/sys/class/thermal/thermal_zone*/temp”)
def getCPUtemperature():
res = os.popen(‘vcgencmd measure_temp’).readline()
#vcgencmd measure_temp -> res=”temp=NN.N’C\n”
#temp =(res.replace(“temp=”,””).replace(“‘C\n”,””))
temp=res[5:9]
try :
temp= float(temp)
except :
print(“vcgencmd measure_temp failed”)
temp=getCPUTemperature2()
return tempdef getCPUTemperature2():
temps=[]
for file_dir in thermal_zones_temp_dirs:
with open(file_dir, “r”) as file:
try :
temps.append(float(file.read()))
except :
print(“Error reading from file {}”.format(file_dir))
continue
if len(temps) == 0:
    print("reading from sys files failed, no CPU temp detected using target_temp")
    temps.append(target_temp * 1000)

return max(temps) / 1000
try:
GPIO.setmode(GPIO.BCM)
GPIO.setup(18, GPIO.OUT)
myPWM=GPIO.PWM(18,50)
myPWM.start(0)

current_speed=minimum_speed

while True:
    temp = getCPUtemperature()

    if(temp<target_temp and not minimum_always_ON):
        myPWM.ChangeDutyCycle(0)
        current_speed=0
        time.sleep(1)
        continue
    if(temp<target_temp and minimum_always_ON):
        myPWM.ChangeDutyCycle(0)
        current_speed=0
        time.sleep(1)
        continue

    if(temp>target_temp and temp<56):
        myPWM.ChangeDutyCycle(40)
        current_speed=40
        time.sleep(1)
        continue
    if(temp>56 and temp<60):
        myPWM.ChangeDutyCycle(50)
        time.sleep(1)
        continue
    if(temp>60 and temp<65):
        myPWM.ChangeDutyCycle(60)
        current_speed=60
        time.sleep(1)
        continue
    if(temp>65 and temp<70):
        myPWM.ChangeDutyCycle(70)
        current_speed=70
        time.sleep(1)
        continue
    if(temp>70 and temp<74):
        myPWM.ChangeDutyCycle(80)
        current_speed=80
        time.sleep(1)
        continue
    if(temp>74 and temp<76):
        myPWM.ChangeDutyCycle(90)
        current_speed=90
        time.sleep(1)
        continue
    if(temp>76):
       #handleFan(100)
        myPWM.ChangeDutyCycle(100)
        current_speed=100
        time.sleep(1)
        continue
except KeyboardInterrupt: # trap a CTRL+C keyboard interrupt
GPIO.cleanup() # resets all GPIO ports used by this program
Tranquilli è finito!
Può sembrare chissà cosa ma in realtà la modifica è molto semplice una volta capito il senso di quello che stiamo guardando, la possibilità di modificare un file di testo per ottenere ciò che vogliamo da una enorme sensazione di potere (come usare il terminale)!!!
Un grazie a Francesco del gruppo telegram che mi ha assistito evitando che facessi esplodere il Rpi 😛
E tu che rapporti hai con i file di configurazione?
Se siete arrivati a leggere fino a qui commentate con “Attenti al Pitone!” 😛
Se apprezzi il mio hobby dai un occhiata agli altri articoli, seguimi su Instagram “https://www.instagram.com/officinadiribby/”, Youtube “https://www.youtube.com/channel/UCwjuFZCIN7IJN_3kuY4pJCA” o iscriviti al mio gruppo Telegram “https://t.me/OdRgroup“ , se preferisci puoi anche scrivermi un email officinadiribby@altervista.org